Harvesting, engineered to adapt.
Senn is a configurable autonomous harvesting system that combines machine vision, intelligent decision-making and precision robotics to identify, pick, place and record individual crops across different harvesting environments.
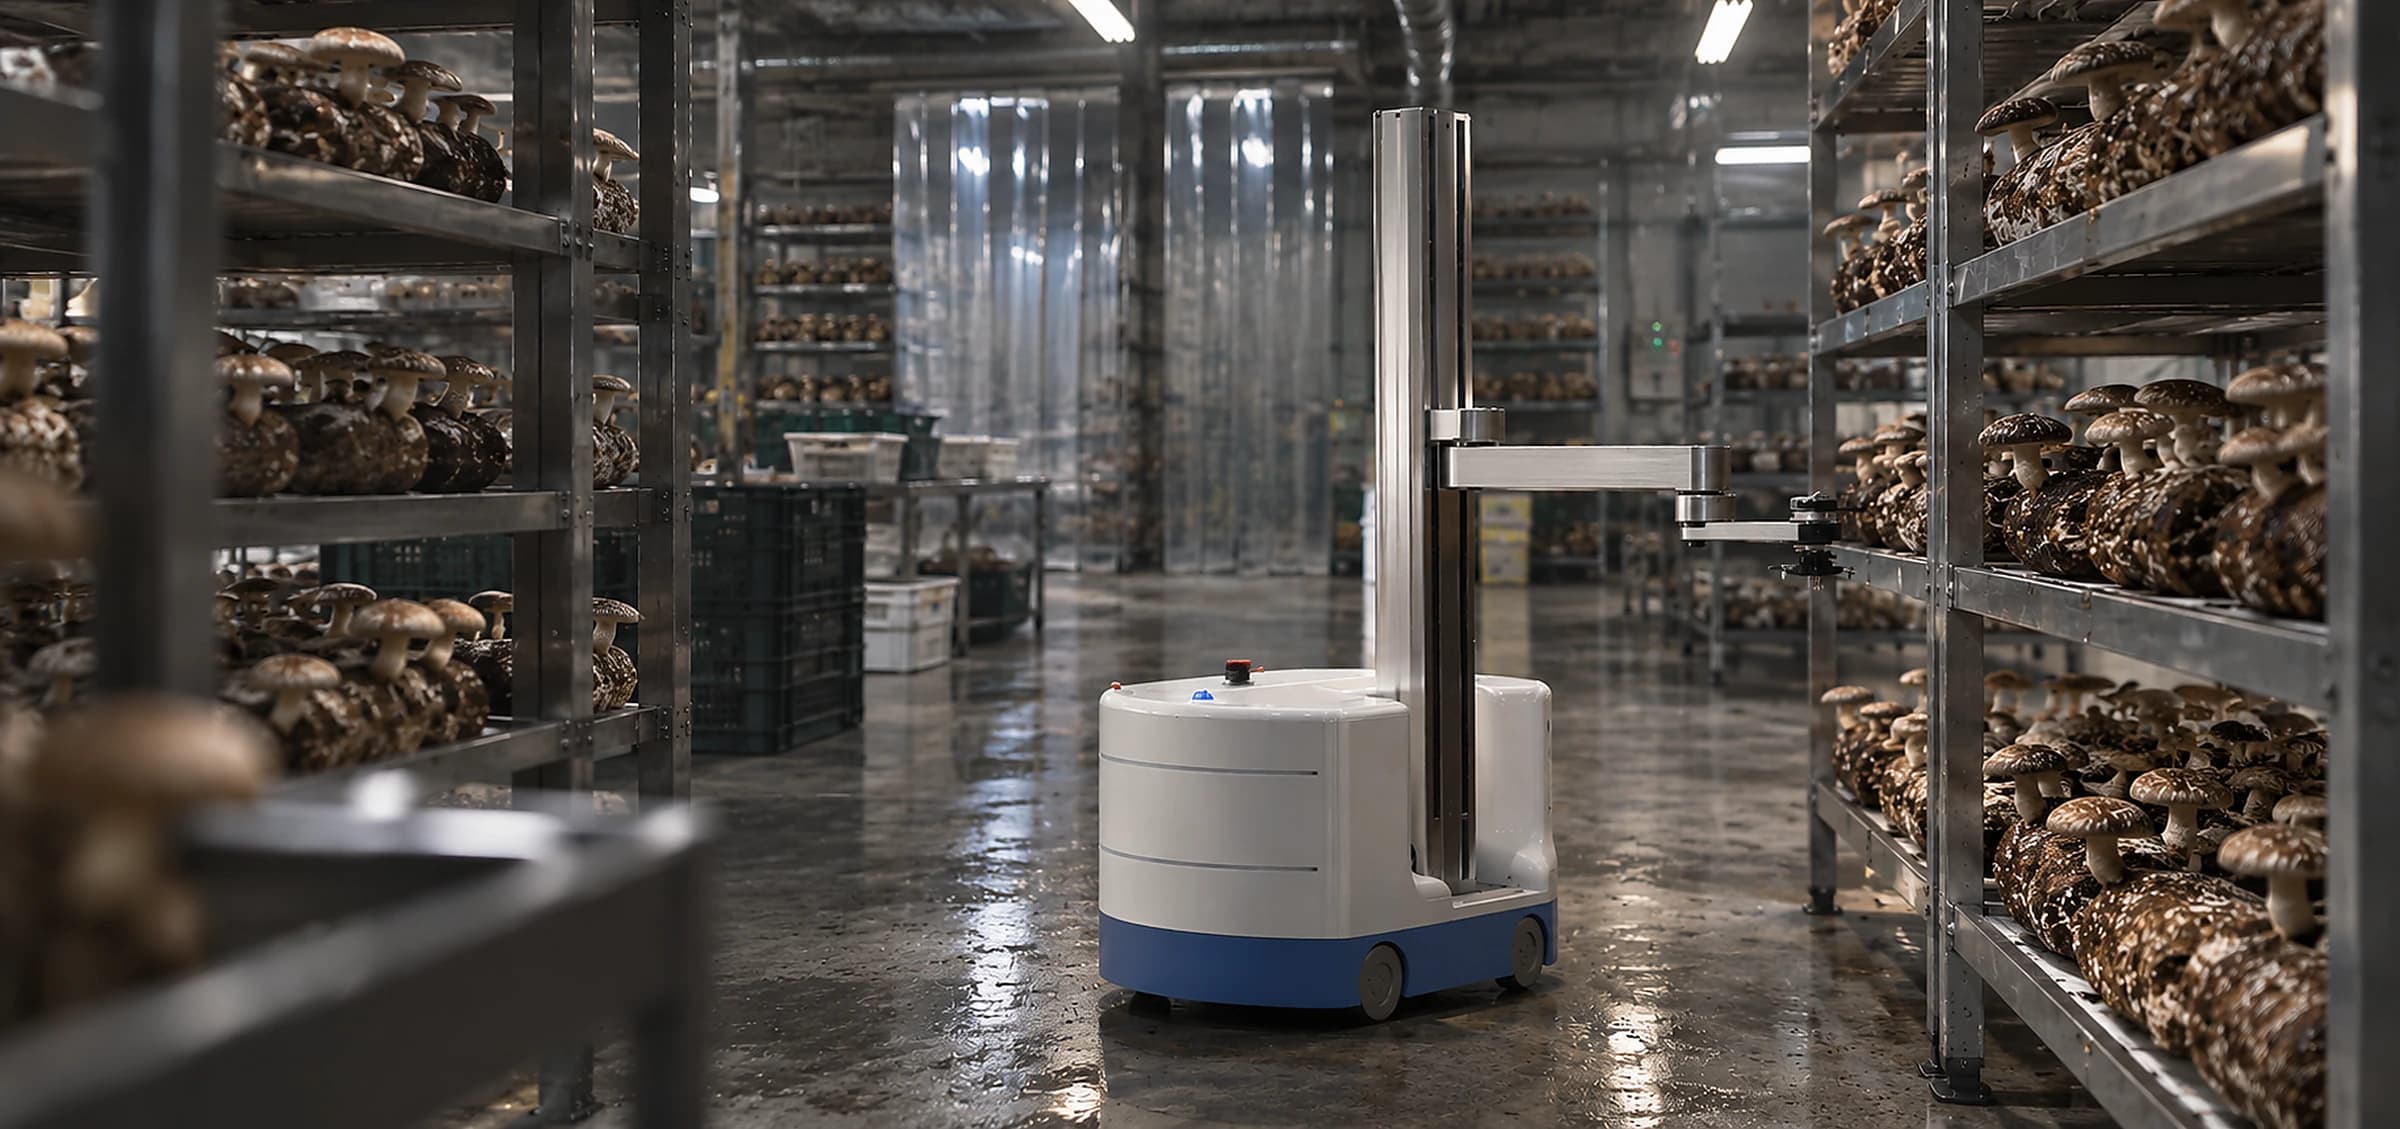
Every crop presents a different harvesting problem.
Harvesting is not simply about moving a robotic arm. The system needs to understand what is present, what is ready, what can be reached, how to approach it, how to pick it, where to place it, and what happened afterward. Different crops and environments introduce different shapes, orientations, densities, growing patterns and access constraints, so the solution has to adapt to the environment rather than repeat a fixed movement.
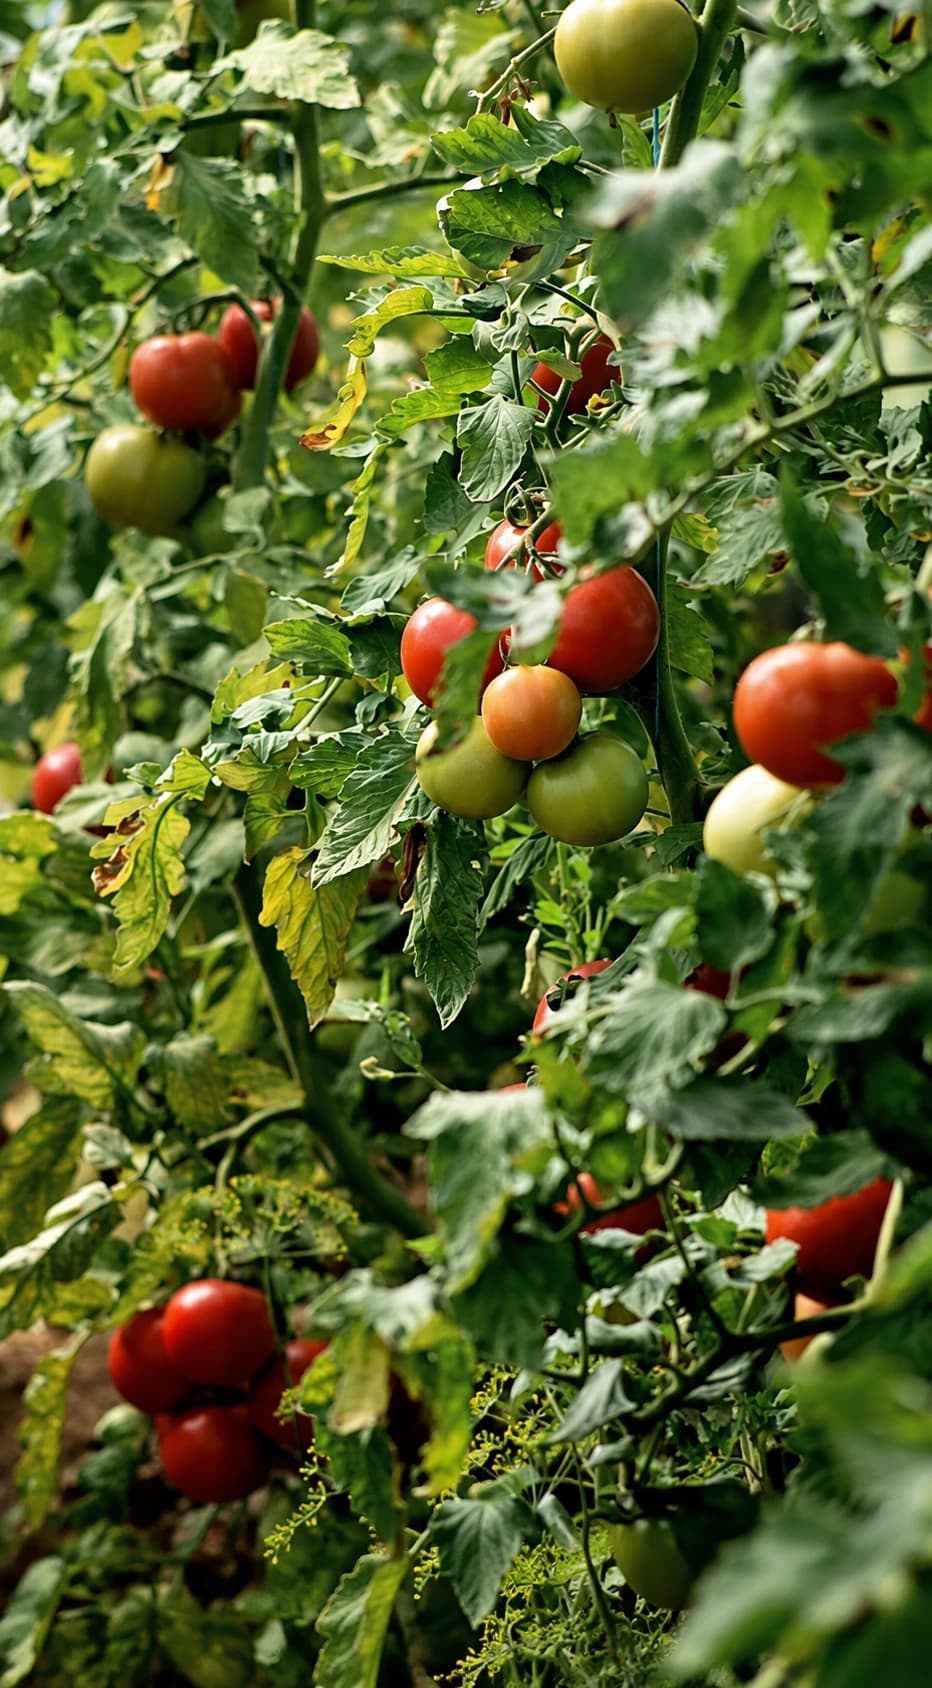
See. Decide. Pick. Place. Record.
Senn detects and understands individual harvest targets, assesses whether each is ready and suitable for harvesting, determines how to approach and grasp it, moves it into its destination under controlled movement, and records what happened, before moving to the next target.
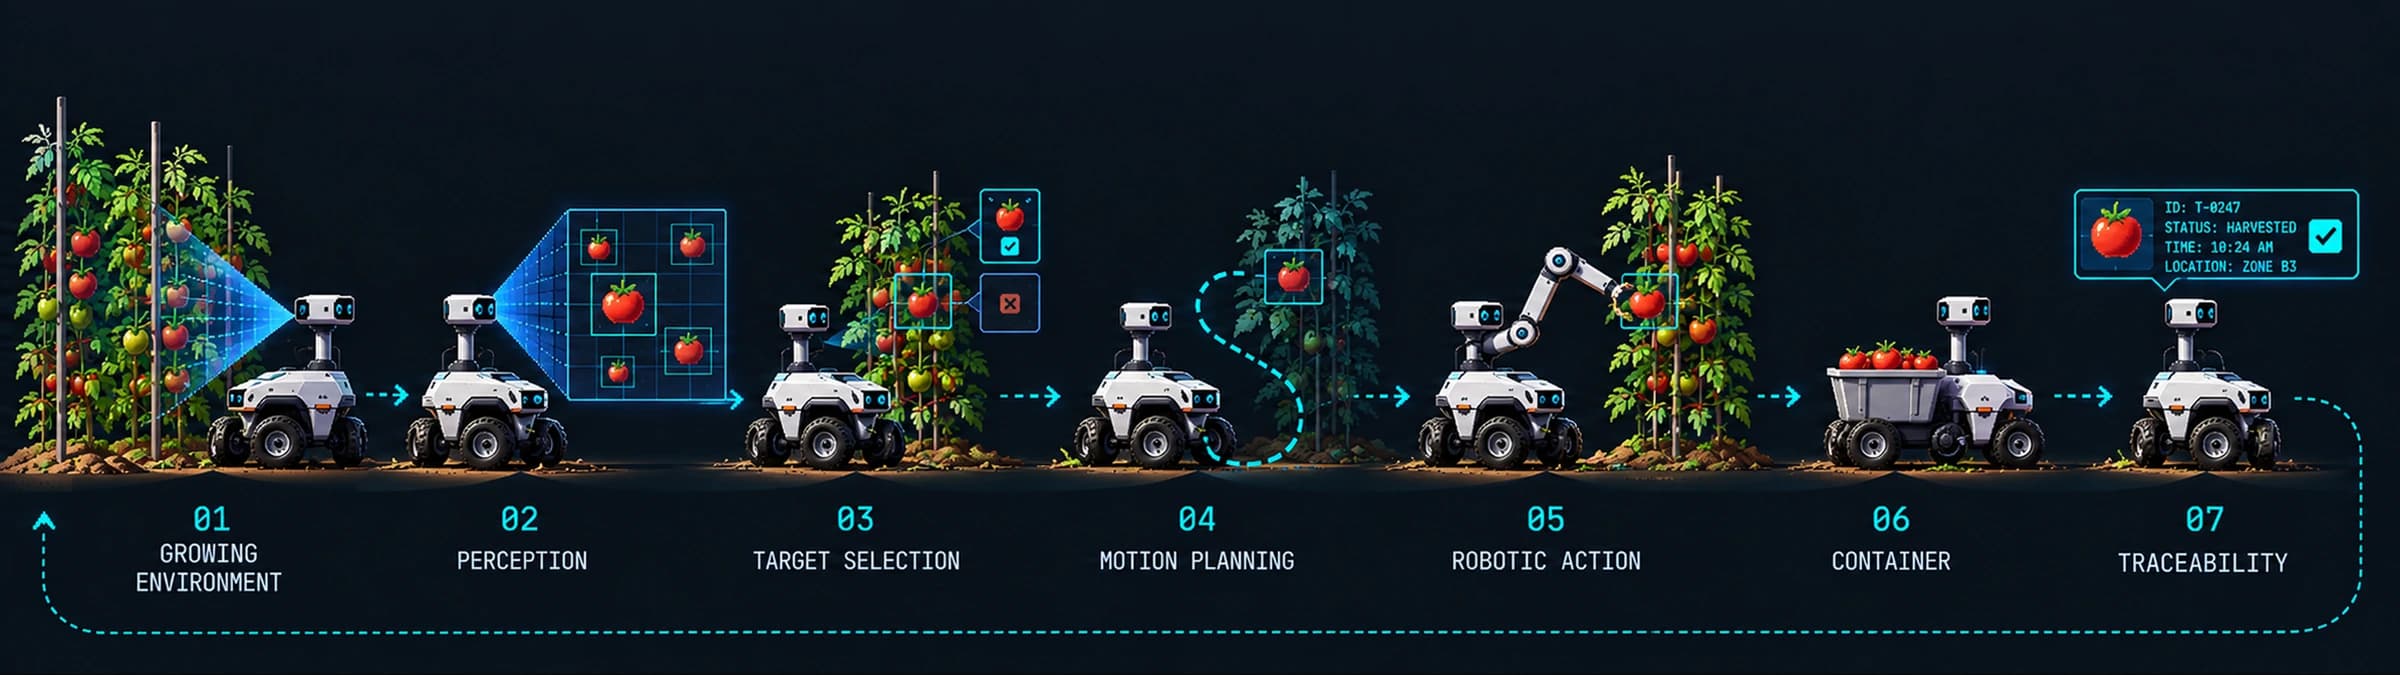
The robot adapts to the harvesting environment.
Senn is not built around one crop. The harvesting system is configured around the application, its growing layout, access and reach, harvesting method, and what needs to be recorded.
Shape, size and how individual items sit within the growing environment.
Vertical, shelved, row-based or another structured arrangement.
How the system approaches and moves around the growing environment.
How an item is grasped, separated and removed.
The gripping mechanism suited to the item being harvested.
Where and how harvested items are placed.
When and how often the system runs its passes.
What needs to be known about each harvest afterward.
Worth being precise about: configuration is engineered per application, not a claim of universal crop compatibility. Each new environment is adapted to, not assumed.
Perception, planning and control working together.
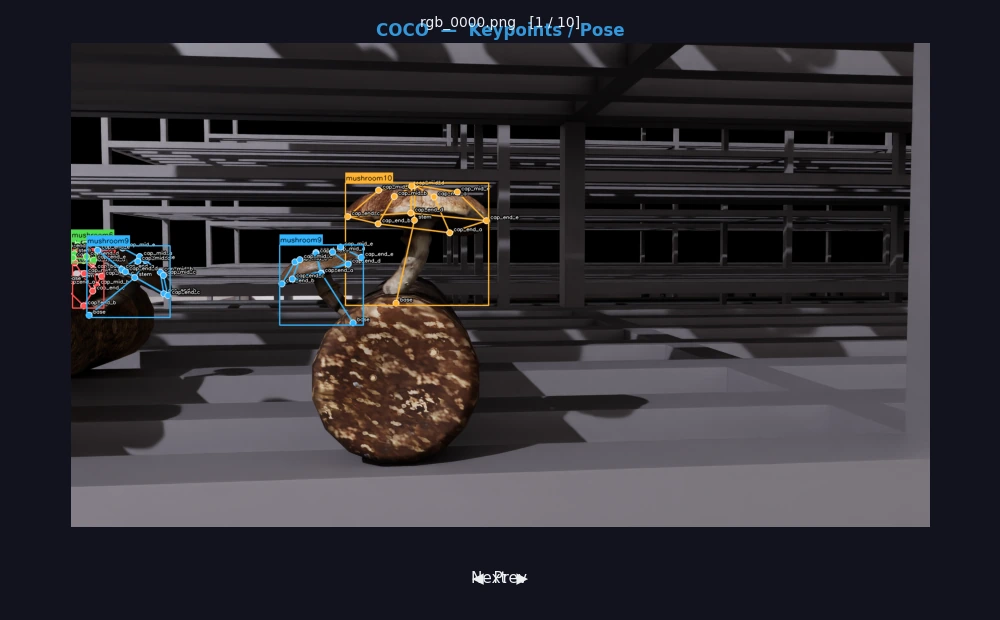
Perception
Computer vision and deep learning interpret the harvesting environment and identify individual targets with sub-millimeter 3D pose estimation.
Planning
Real-time motion planning evaluates the environment and determines how the robot can reach and interact with the selected target without collision.
Control
A governed control layer ensures movement commands pass through controlled checks before reaching the machine end-effector and mobile base.
Designed for different harvesting environments.
From mushroom harvesting to other structured crop environments, Senn can be configured around the harvesting conditions and workflow of each application.
Mushroom Harvesting
Individual mushroom detection, readiness assessment, selective picking, controlled placement and per-item records.
Vertical Farming
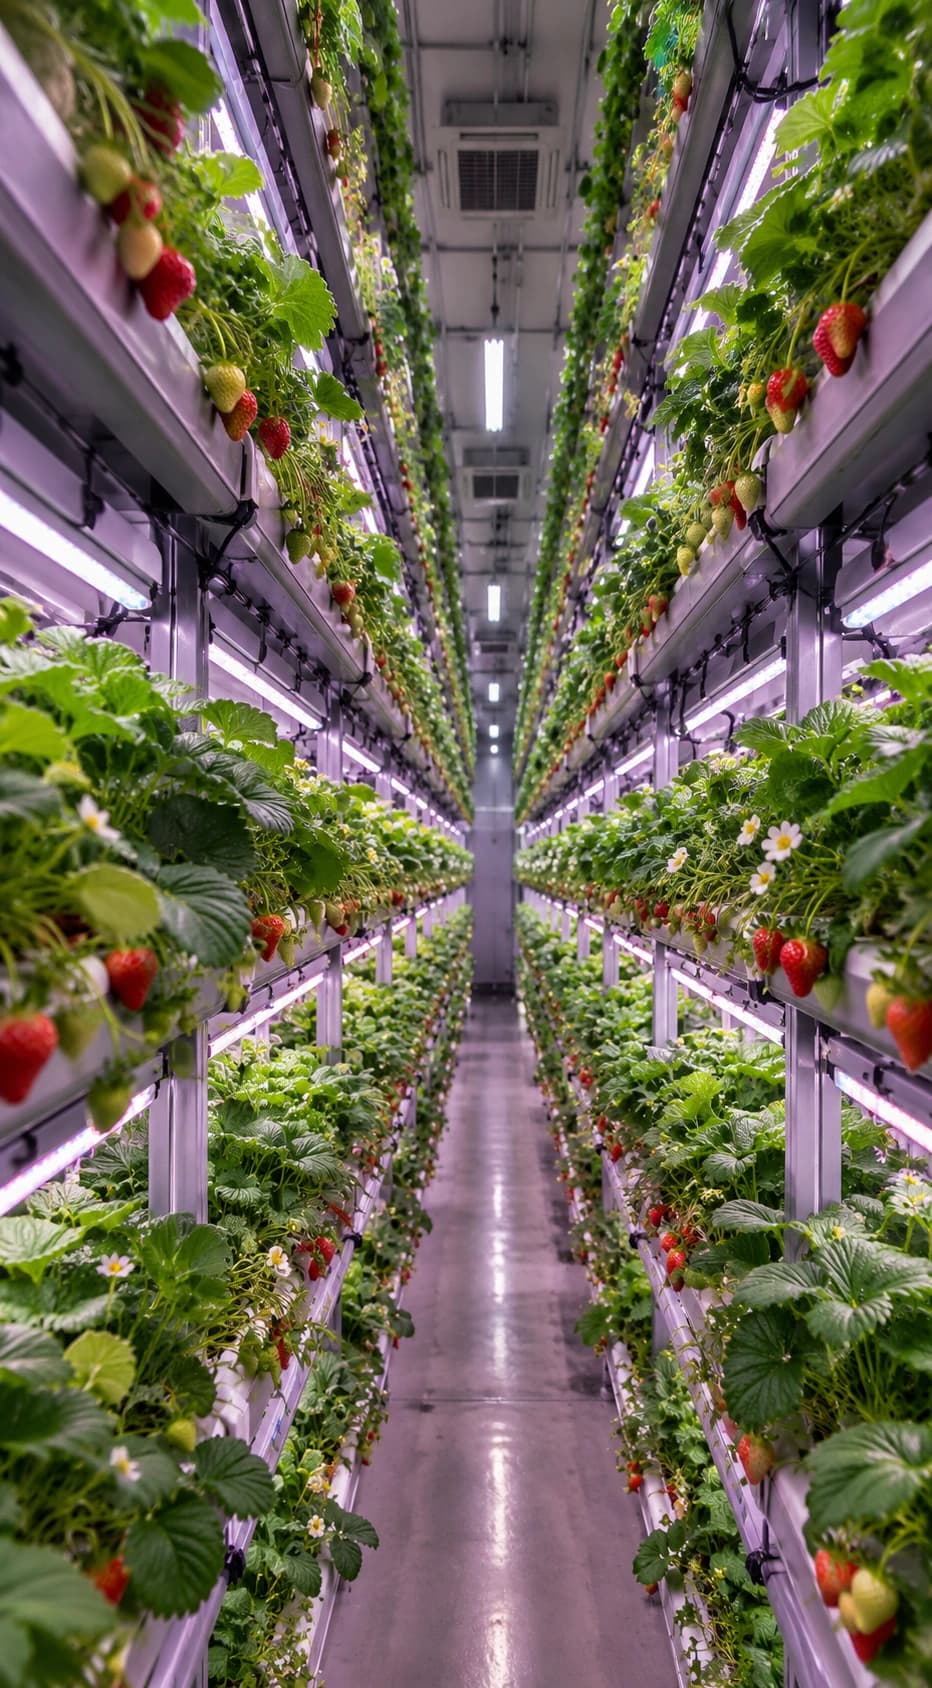
Adaptation for structured vertical growing environments where crop position, access and harvesting conditions can be defined.
Row-Based Crops
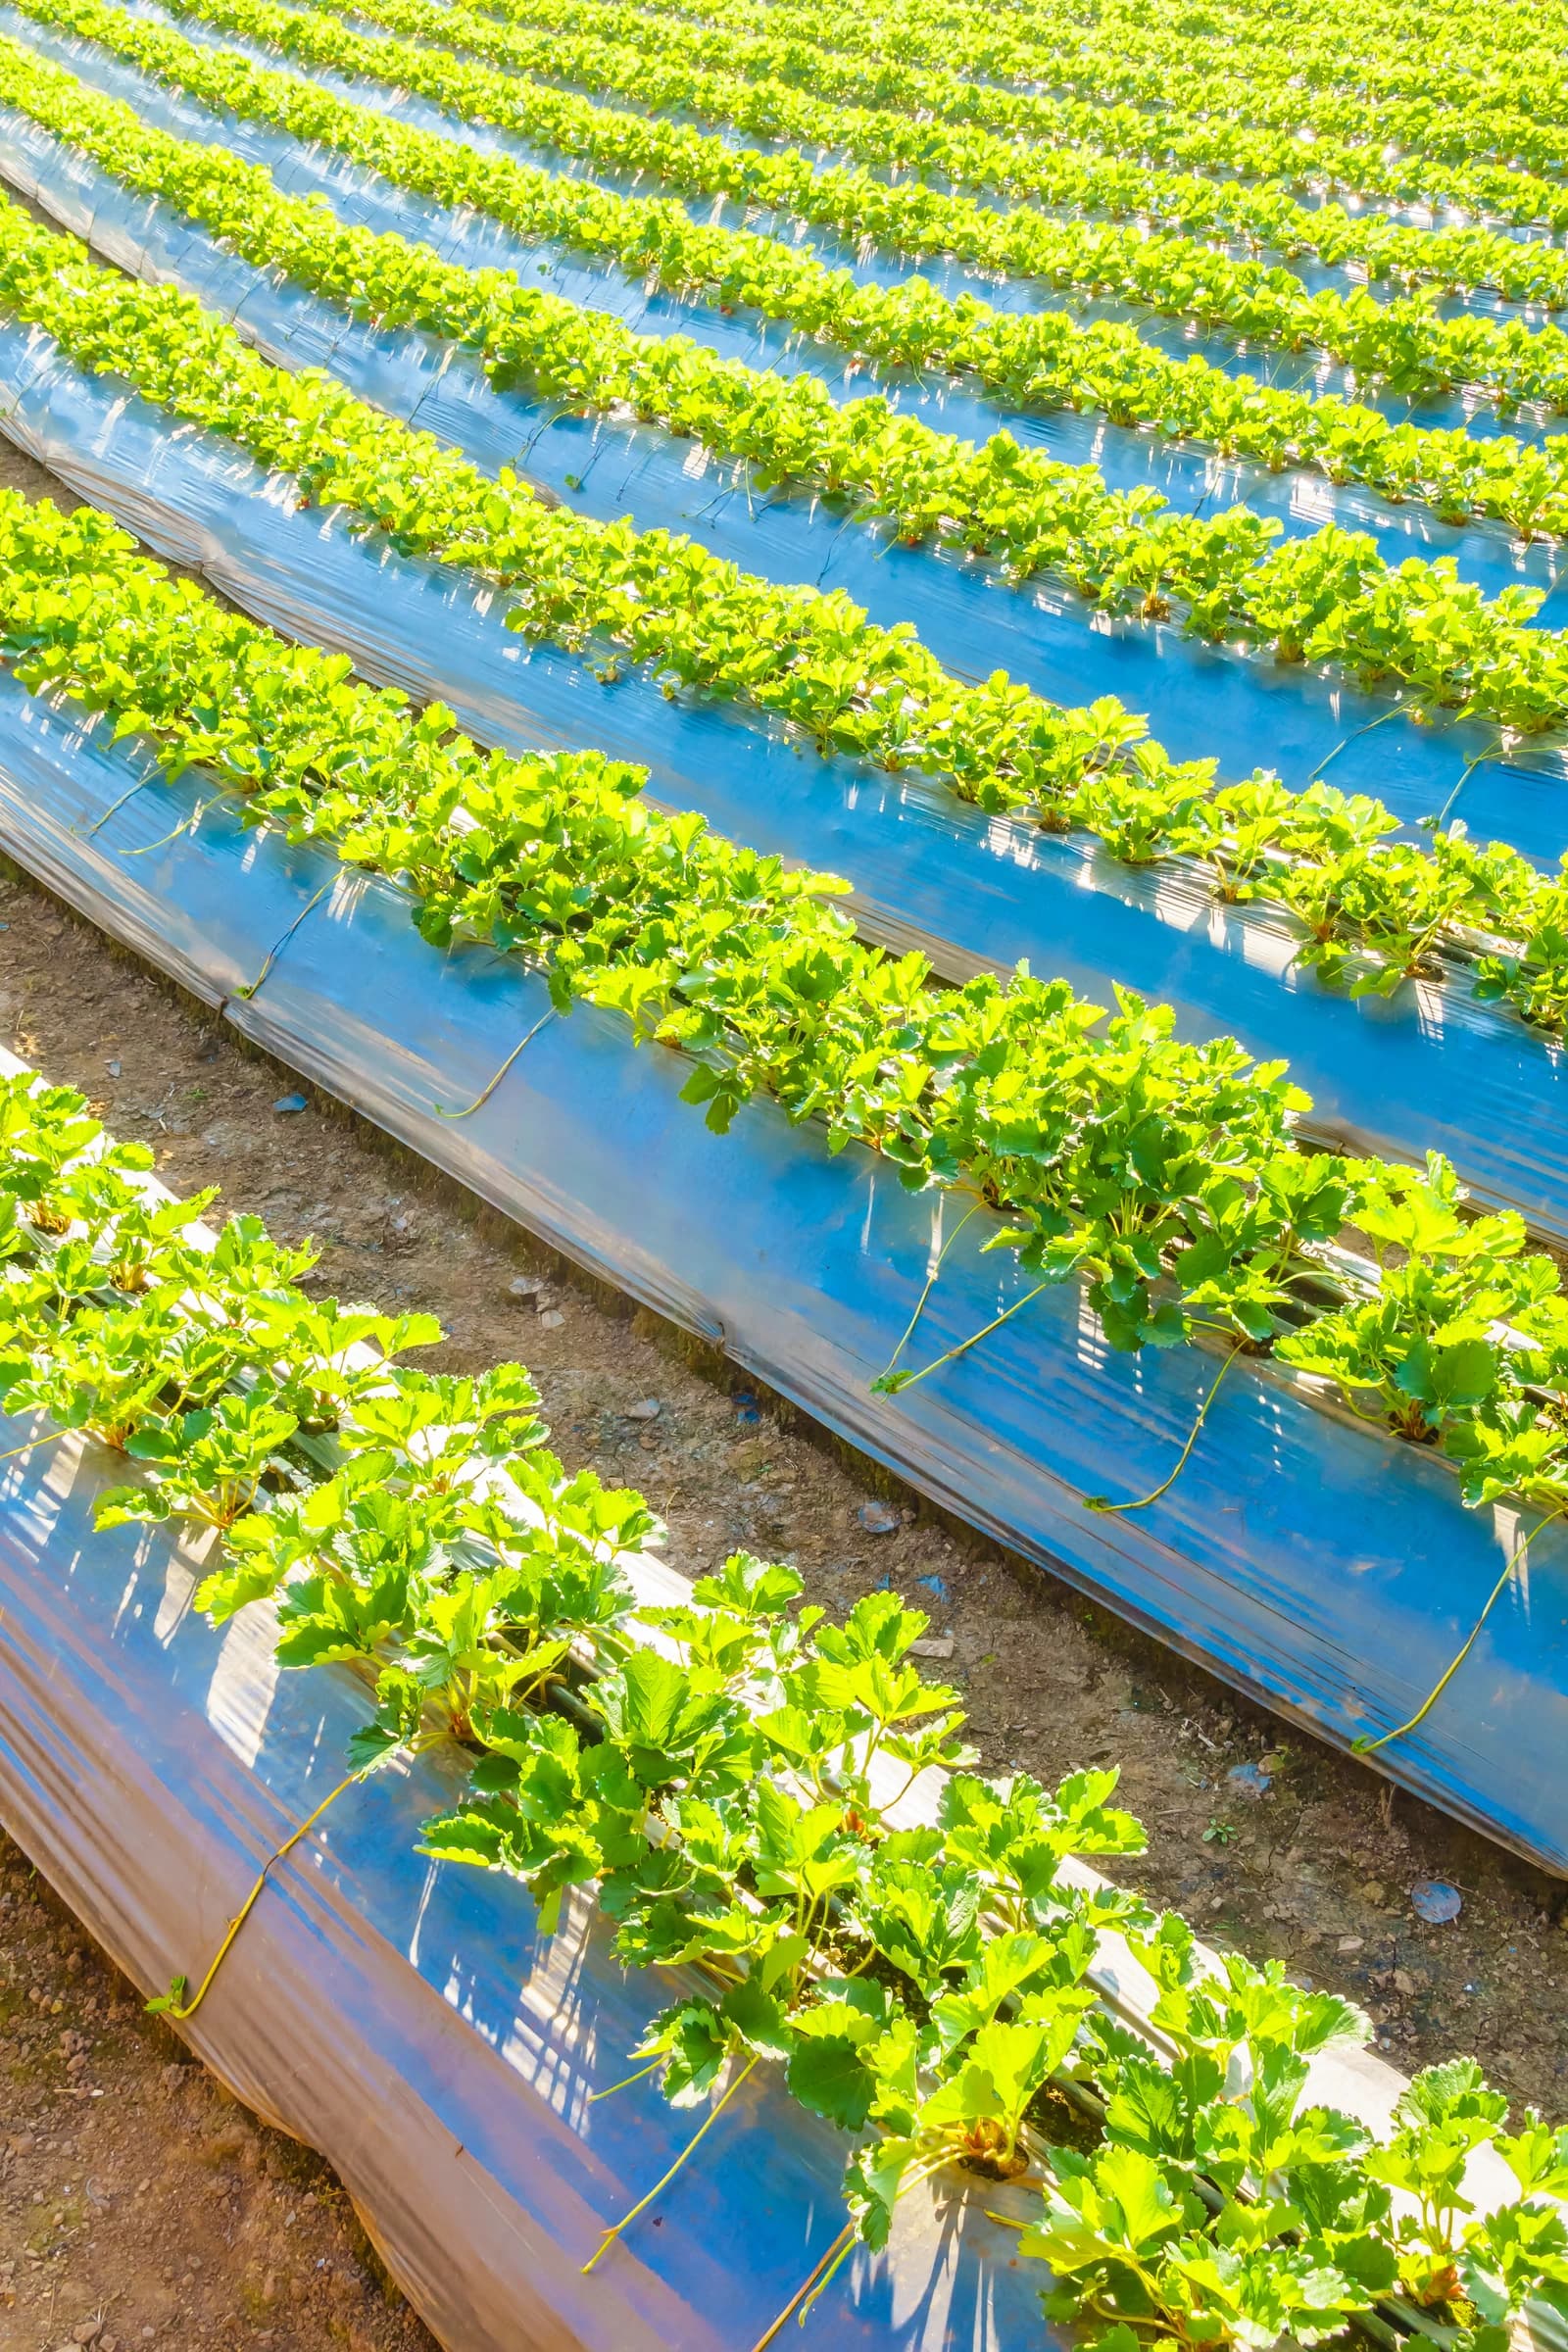
Adaptation for environments where crops are arranged in rows and the robot can plan movement around the growing layout.
Custom Applications
Configure the system around a specific crop, harvesting process or operating environment.
From one harvesting pass to the next.
Senn can operate according to a defined schedule, work through assigned harvesting areas, assess individual targets, and continue through repeated passes, supporting follow-up harvesting based on previous records.
Know what was harvested.
And what was left behind.
Depending on the configured application, Senn can maintain information around what was harvested, what was left, what was not attempted, why, when it happened and where it came from.
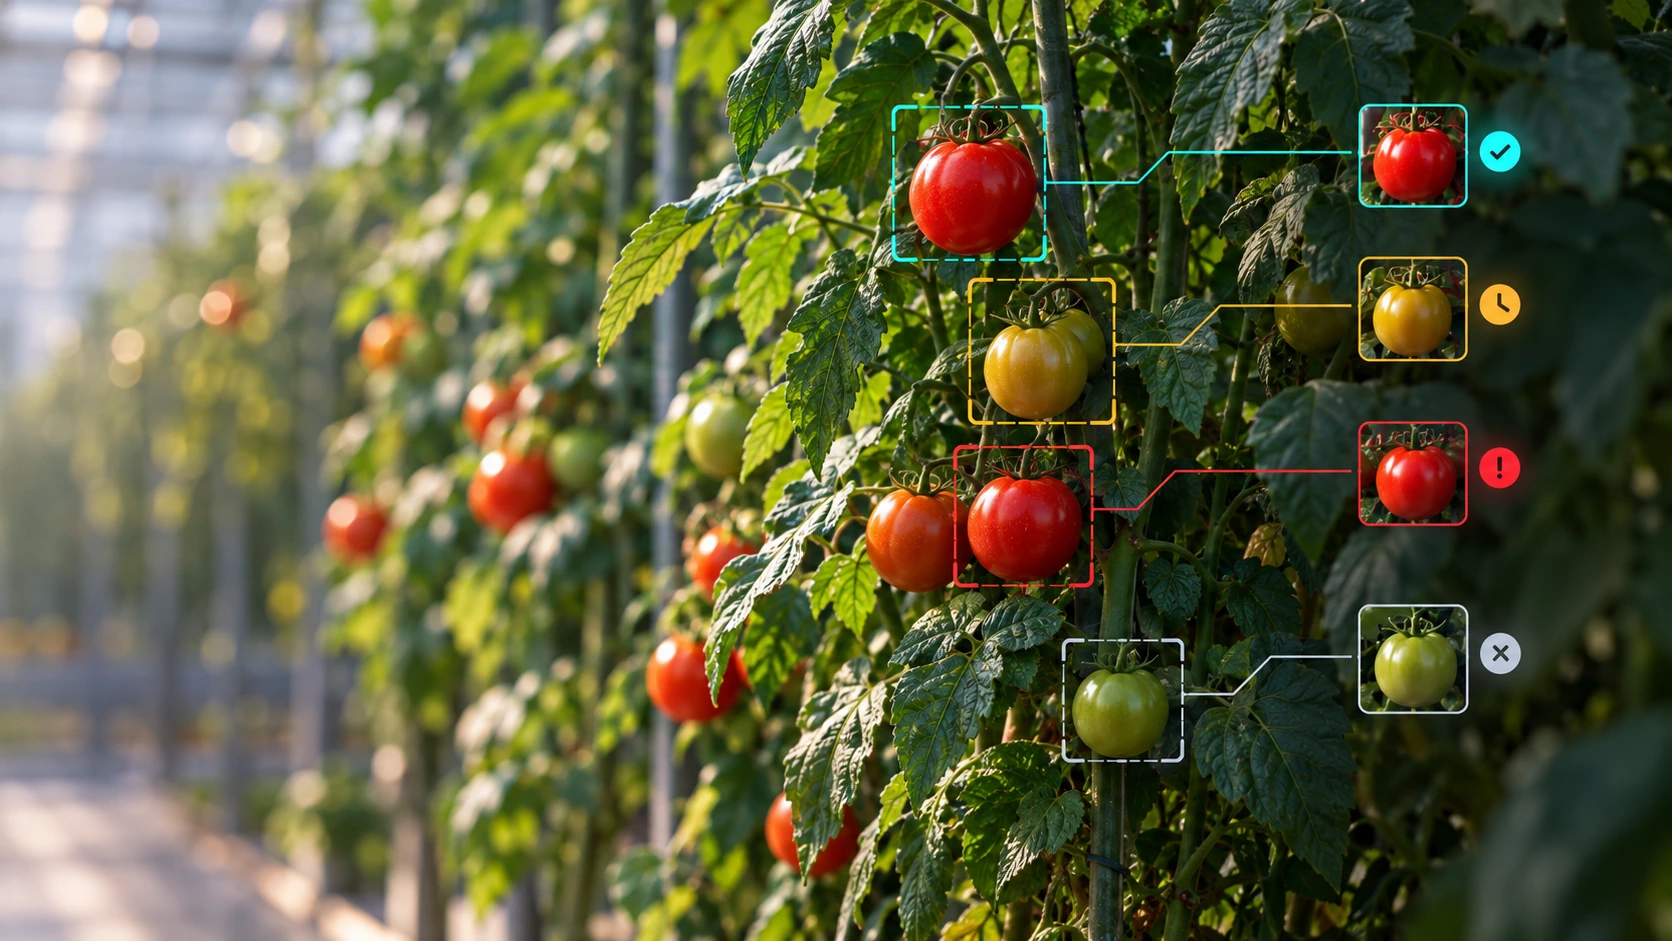
Have a harvesting problem to engineer around?
Tell us about your crop, environment and harvesting workflow. Veyrion can help explore how autonomous robotics can be configured around your application.